
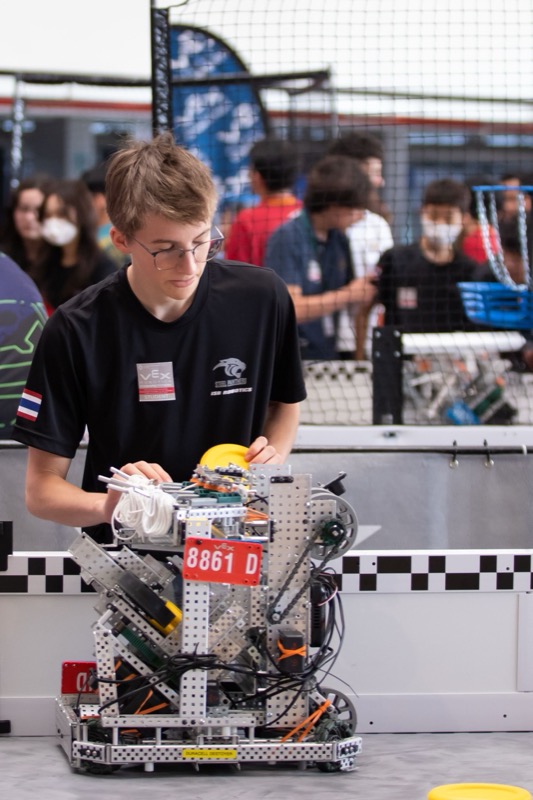
Photos of my life
Move your mouse across the banner to reveal glimpses of my experiences, travel, and moments.
AI Researcher & Software Engineer
B.Sc. Honours Computer Science student at McGill University (CGPA 3.77) specializing in Deep Reinforcement Learning, SLAM algorithms, and industrial simulation.
Hi, I’m Jonathan Lamontagne-Kratz. I am an AI researcher and software engineer focused on developing novel reinforcement learning algorithms, autonomous robotics systems, and high-performance simulation engines.
I am currently pursuing my B.Sc. Honours in Computer Science at McGill University (CGPA 3.77 / 4.00), following my IB Diploma with High Honours (42/45 score) at the International School of Bangkok. At McGill, my research spans deep reinforcement learning, stochastic multi-agent environments, and bio-inspired SLAM algorithms.
My research portfolio includes authoring an MSURJ poster presentation on integrating SOTA MuZero advancements (EfficientZero V2, Gumbel MuZero) for stochastic multi-agent decision environments—developing “RainbowZero,” an agent for Settlers of Catan. I’ve also served as RL Research Lead at the McGill Student AI Research Lab, leading teams to implement MCTS, AlphaZero, and RainbowDQN from scratch.
In applied research, I’ve architected Python-based Discrete Rate Simulation (DRS) engines for mining fleet management in Prof. Navarra’s Lab (see Mining-DRS), co-authored work on bio-inspired RatSLAM 2.0 in Prof. Schwarz’s Lab (see VectorHaSH), built telemetry and LLM error diagnosis pipelines at Retail Realm, and researched LLM enterprise automation at Edgenda.
Stochastic MuZero, Multi-Agent RL (PettingZoo), MCTS, SLAM (RatSLAM, VectorHASH), and LLM telemetry pipelines.
McGill B.Sc. Honours CS (CGPA 3.77 / 4.00), IB Diploma Score 42/45, 3rd Place Winner at Aldo AI Hackathon ($1,500).
From C++ PID control loops in VEX Robotics to Python-first discrete simulation engines and scalable full-stack applications.
Where It All Began: My Coding & Global Journey
From building lunch-break games in Myanmar to competing at the VEX Robotics World Championship in Thailand.
Canada & Qatar
Born in Canada and moved to Doha, Qatar at age 3. My interest in software first sparked in 6th grade when I built my very first playable game for a school class project.
Myanmar & Game Development
Moving to Myanmar, programming became an obsession. I dove into GameMaker Studio 2, creating custom multiplayer games for my friends and me to play during lunch breaks at school.
Thailand & VEX Worlds
In 9th grade in Bangkok, Thailand, I joined VEX Robotics, rising to Team Captain & Systems Engineer. Writing C++ PID control loops for autonomous robots took us to the VEX World Championship.
McGill & AI Research
That journey from 2D game mechanics to autonomous robotics led directly to my B.Sc. Honours CS degree at McGill University (CGPA 3.77) and my research in Deep Reinforcement Learning.
Research & Work History
A comprehensive record of research appointments, AI lab positions, and robotics engineering roles.
Independent RL Researcher
Authored and presented research on advancing MuZero architectures for stochastic multi-agent environments.
Key Highlights & Contributions
- Authored research detailing the integration of MuZero advancements (EfficientZero V2, Gumbel MuZero) into multi-agent systems.
- Engineered 'RainbowZero,' a superhuman custom agent architecture designed for Settlers of Catan.
- Presented empirical benchmarks and multi-agent state space representations at MSURJ poster session.
Research Intern
Architecting automated telemetry systems, log correlation pipelines, and LLM diagnostic integrations.
Key Highlights & Contributions
- Architected a Python-based telemetry tool to unify multi-line payment system logs with a time-windowed correlator.
- Engineered automated data pipelines that calculate hardware clock drift, normalize log formats, and mask PII/PCI data.
- Prototyped LLM integrations to analyze filtered error datasets and generate actionable remediation steps for system failures.
Researcher
Designing Python-based Discrete Rate Simulation (DRS) engines for complex industrial mining operations.
Key Highlights & Contributions
- Architected a Discrete Rate Simulation (DRS) engine to model mining operations, dynamic mass balance, and fleet logistics.
- Translated theoretical operating modes into programmatic simulation components for journal paper publication.
- Engineered a Python-first modeling framework utilizing execution contexts for dependency tracing in industrial applications.
AI Researcher Intern
Researched LLM architectures and automated data pipelines for enterprise automation systems.
Key Highlights & Contributions
- Researched LLM architectures and their application in enterprise automation systems to guide product strategy.
- Developed data pipelines to process and visualize complex model performance metrics for non-technical stakeholders.
- Collaborated with cross-functional teams to integrate LLM capabilities into enterprise software solutions.
Reinforcement Learning Research Lead
Led research teams in recreating seminal RL papers and building core algorithms from scratch.
Key Highlights & Contributions
- Led a research team to recreate key RL papers, including AlphaZero, MuZero, PPO, and RainbowDQN.
- Implemented Monte Carlo Tree Search (MCTS) and Deep Q-Learning from scratch while overseeing system architecture.
Undergraduate Researcher
Researching bio-inspired SLAM algorithms and cognitive mapping simulations.
Key Highlights & Contributions
- Implemented key components of the SLAM algorithm based on RatSLAM and VectorHASH for efficient mapping.
- Co-authored an article on RatSlam 2.0 (Bio-inspired SLAM).
- Developed Python simulations for cognitive mapping and performed statistical analysis to validate algorithmic convergence.
Team Captain & Lead Systems Engineer
Led autonomous robotics design, PID control loop development, and sensor fusion engineering.
Key Highlights & Contributions
- Engineered autonomous robots using C++ and custom PID control loops for precise motion profiling.
- Implemented sensor fusion combining odometry and vision sensors to automate complex field tasks.
- Upgraded PID software system and joystick controls for the McGill Autonomous Underwater Vehicle (AUV) using Python and Rospy.
Skills, Frameworks & Certifications
Derived from research implementations, competition projects, and academic coursework.
AI, RL & Machine Learning
Deep reinforcement learning, search tree algorithms, multi-agent frameworks, and neural architectures.
Languages & Mathematics
Core programming languages, scripting tools, numerical computing, and mathematical foundation.
Libraries, Robotics & Systems
Data science suites, mobile/web frameworks, SLAM algorithms, and robotics software.
Certifications & Awards
Hackathon achievements, certified courses, and multilingual fluency.
Education, Key Projects & Interests
Formal degrees, high-impact projects, and personal endeavors outside research.
B.Sc. Honours Computer Science
IB Diploma • Graduated with High Honours (May 2023)
Key Coursework
Signature Projects
Advanced RL Framework
Superhuman Stochastic MuZero agent for Settlers of Catan via PettingZoo. Modular RL library with EfficientZero V2, Gumbel MuZero, and RainbowDQN.
ALDO AI Outfit Builder
3rd place winner at Aldo AI Hackathon. Embeddable AI widget generating occasion-aware outfits with head-to-toe visualization & item swapping.
Pantry Pilot AI
Smart household pantry management & meal planning platform featuring Vision AI for receipt/fridge item extraction & recipe recommendations.
Let’s Connect & Collaborate
Whether you’re interested in reinforcement learning research, software engineering opportunities, or algorithmic optimization, feel free to reach out.